About Me
I am Kadir Yavuz Kurt, a Control and Automation Engineering student at Istanbul Technical University. My research interests focus on humanoid robots, legged locomotion systems, and the application of reinforcement learning for robotic control.
Currently, I am conducting research on legged robotics at the ITU Robotics Laboratory, where I contribute to various research projects in the field focusing on Wheeled-Legged Locomotion and Humanoid Robot Motion Generation.
Publications
Conference Papers
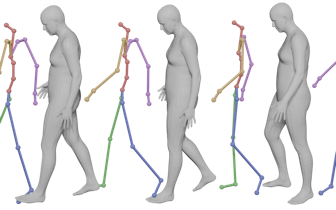
A controlled benchmark of MDM, MotionDiffuse, and ReMoDiffuse on HumanML3D under identical conditions, adding jerk and foot-sliding metrics and a per-action analysis that reveals differences hidden in aggregate scores.
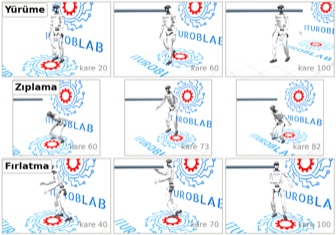
Motions from three text-to-motion diffusion models are retargeted to the Unitree G1 and tracked by reinforcement learning policies in simulation, showing that GMR beats PyRoki on foot slip and stance clearance and that no generation metric reliably predicts retargeting quality.